Subagents
SubAgents lets an agent delegate self-contained tasks to named child agents. It takes a sequence of SubAgent entries and exposes a single delegate_task(agent_name, task) tool. Each delegation runs the chosen sub-agent in its own run — with its own message history, so it never sees the parent conversation — and returns its output to the parent.
While Pydantic AI Harness is on 0.x releases, the API may change between minor releases; when it does, deprecation warnings and release-note migration guidance tell you (or your agent) exactly how to upgrade. See the version policy.
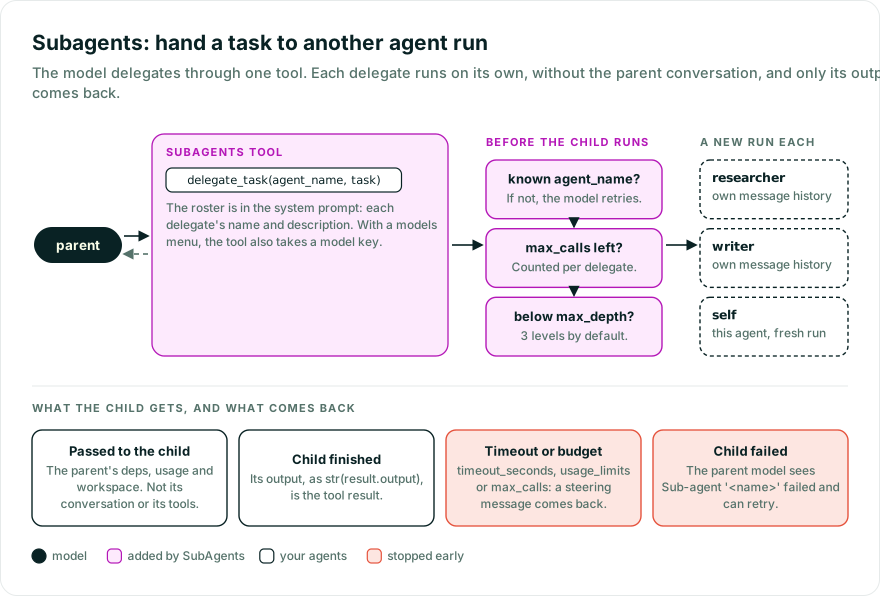
A single agent that does everything accumulates a large tool set and a long context. Splitting the work across specialized sub-agents keeps each context focused, but wiring up delegation by hand means writing a tool per agent, forwarding deps, threading usage limits, and telling the model what it can delegate to.
SubAgents takes a sequence of SubAgent entries and exposes a single delegate_task(agent_name, task) tool. Each delegation runs the chosen sub-agent in its own run — with its own message history, so it never sees the parent conversation — and returns its output to the parent. The available sub-agents are listed in the system prompt, so the listing stays in the cached prefix; if it changes between runs of the same conversation, the change is appended instead of rewriting the prefix.
from pydantic_ai import Agent
from pydantic_ai_harness import SubAgent, SubAgents

researcher = Agent('anthropic:claude-opus-5-5', name='researcher', description='Researches a topic and reports findings')
writer = Agent('anthropic:claude-opus-5-5', name='writer', description='Turns notes into polished prose')

orchestrator = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[SubAgents(agents=[SubAgent(researcher), SubAgent(writer)])],
)

result = orchestrator.run_sync('Research the history of TLS and write a one-paragraph summary.')
print(result.output)
A delegate’s name — how the parent model refers to it, and how it is listed in the prompt — is the agent’s own name, or a SubAgent(name=...) override. Two delegates resolving to the same name is an error, and an agent with no name and no override is rejected.
| Tool | Purpose |
|---|---|
delegate_task(agent_name, task) | Run the named sub-agent on a self-contained task and return its output. |
- The sub-agent runs with its own message history, so
taskmust be self-contained. - An unknown
agent_nameraisesModelRetry, so the model can correct itself. - The result returned to the parent is
str(result.output). - With a
modelsmenu configured, the tool takes an extramodelargument (see below).
- Deps are forwarded. The parent run’s
depsare passed to each sub-agent, so sub-agents share the parent’sAgentDepsT(enforced by the type signature — every sub-agent is anAbstractAgent[AgentDepsT, Any]). - Delegated agents inherit the parent’s workspace unless
workspace_resolverselects another directory. Parent read-only restrictions still apply. - Usage is shared by default. The parent’s
usageis passed to each sub-agent run, so token usage aggregates and a parentusage_limitsapplies across the whole agent tree. Setforward_usage=Falseto give each sub-agent run its own accounting. - The parent’s tools are not passed on. A sub-agent runs with its own tools. To delegate to an agent that has all of the parent’s tools and capabilities, use
include_self=True(see “Delegating to the agent itself” below). - Capabilities can be shared.
shared_capabilitiesare applied to every sub-agent run — e.g. give all sub-agents a common guardrail, memory, or planning capability without rebuilding eachAgent. - Sub-agent events can be streamed. Pass an
event_stream_handlerand it’s forwarded to each sub-agent run, so the sub-agent’s model-streaming and tool events surface to the caller (the handler receives the sub-agent’s ownRunContext).
inherit_tools=True is deprecated and emits a HarnessDeprecationWarning. It adds the parent agent’s own tools (registered via tools= or toolsets=) to each sub-agent run, minus the delegate tool, but not the tools contributed by the parent’s capabilities. Bind the tools an explicit sub-agent needs directly to its Agent, use include_self=True to delegate to a fresh run of the agent with everything bound to it, or use a tool_resolver to give disk-loaded agents tools.
With include_self=True, the roster also lists the running agent itself, as self. A delegation to self starts a fresh run of that agent (RunContext.agent) on the parent run’s model (or the models option the parent picks), with no parent conversation. Because the child is the same Agent, it has every capability, toolset, and instruction bound to it, and they register again in the child run: a guardrail, approval gate, or audit hook bound next to SubAgents sees the tool calls the delegate makes, not only the delegate_task call. This is what Coder uses by default.
from pydantic_ai import Agent
from pydantic_ai_harness import SubAgents

agent = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[SubAgents(include_self=True)],
)
- Only what is bound to the
Agentcarries over. Capabilities, toolsets, instructions, and model settings passed to the parent’srun()are not part of the agent, so the delegate does not get them. PassingSubAgents(include_self=True)itself torun()raises aUserErrorwhen the run starts, since the delegate would come up without it. - Delegation depth is capped. The delegate carries
delegate_tasktoo, somax_depth(default3, counting the top-level run) bounds the tree: the top-level run delegates, its delegates delegate once more, and a run at the limit gets neitherdelegate_tasknor the sub-agent listing. The limit applies to every delegation throughSubAgents, including explicit rosters. - Delegates inherit everything, including what may not suit a sub-task. An
AskUsercapability bound to the agent can prompt the user from inside a delegation, and the delegate returns the agent’s ownoutput_type, rendered withstr()(a delegate run that ends withDeferredToolRequestsorPendingModelResponsereturns a steering message instead, as described under failure handling). - The deprecated
inherit_toolsdoes not apply toself, whose tools are already the parent’s. The nameselfis reserved: an explicit delegate with that name is an error, and a disk definition with that name is skipped with a warning. - On Temporal,
agent_foldersis not supported. Sub-agents read fromagent_foldersadd a toolset at run time, which Temporal refuses, so passagent_folders=None. Whenselfis the only delegate, it runs in the workflow, so register aModelinstance frommodelswithTemporalDurability(models=...). Otherwise delegations run in an activity, or in a child workflow when you opt in (see Delegates as child workflows), neither of which has access to the parent run’s model, so a delegate needs a model of its own (or, in an activity, amodelsoption); see delegation on Temporal.
Each SubAgent carries its own budgets, so one delegate’s controls do not touch the others. A SubAgent with no controls set runs with the SubAgents defaults.
from pydantic_ai import Agent
from pydantic_ai.usage import UsageLimits
from pydantic_ai_harness import SubAgent, SubAgents

reproducer = Agent('anthropic:claude-opus-5-5', instructions='Reproduce the reported bug from a minimal script.')
librarian = Agent('anthropic:claude-opus-5-5', instructions='Find relevant docs, issues, and prior art.')

orchestrator = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[
        SubAgents(
            agents=[
                SubAgent(reproducer, usage_limits=UsageLimits(request_limit=35), timeout_seconds=600, max_calls=1),
                SubAgent(librarian, usage_limits=UsageLimits(request_limit=18), timeout_seconds=300, max_calls=2),
            ]
        )
    ],
)
| Field | Effect |
|---|---|
models | Which keys of the SubAgents model menu this delegate may run on, and which one it runs on by default: the first key listed. See “Per-delegation model selection” below. |
usage_limits | A request/token budget for one delegation. The child runs with its own usage accounting, so the budget counts only that child’s requests and tokens (not the parent’s or siblings’). With forward_usage=True, the child’s usage is added to the parent’s usage after the delegation. Reaching the budget is a soft outcome (see below), not a run-stopping UsageLimitExceeded. |
timeout_seconds | A wall-clock budget for one delegation. When the child exceeds it, its run is cancelled and the parent gets a soft steering message instead of hanging on the child. The cancelled child’s event_stream_handler (if any) stops receiving events without a terminal event. |
max_calls | The maximum number of delegations to this sub-agent per parent run. Once reached, further delegations return a soft budget-exhausted message without running the child. Counts are scoped to one Agent.run (a run_id) and cleared when it ends, so each parent run and each level of a nested tree budgets independently. |
on_failure | A steering message returned to the parent for any soft degradation of this delegate, in place of the built-in default. Setting it also makes child failures soft (see below). |
contain_errors | Whether an unexpected crash in this delegate is caught and returned to the parent as a bounded ModelRetry instead of aborting the parent run (see below). Unset inherits the SubAgents(contain_errors=...) default (off). |
The orchestrator knows how hard a task is at the moment it writes the brief, so it is the right place to decide which model runs it. Configure a models menu and the delegate tool gains a model argument that names one of its keys.
from pydantic_ai import Agent
from pydantic_ai.settings import ModelSettings
from pydantic_ai_harness import SubAgent, SubAgents
from pydantic_ai_harness.subagents import ModelOption

reviewer = Agent('anthropic:claude-opus-5-5', name='reviewer', description='Reviews a diff')
linter = Agent('anthropic:claude-opus-5-5', name='linter', description='Runs the linter and reports failures')

orchestrator = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[
        SubAgents(
            agents=[SubAgent(reviewer), SubAgent(linter, models=['fast'])],
            models={
                'fast': 'anthropic:claude-haiku-5-5',
                'standard': 'anthropic:claude-sonnet-5-5',
                'deep': ModelOption(
                    'anthropic:claude-opus-5-5',
                    description='hard reasoning, multi-file changes',
                    settings=ModelSettings(thinking='xhigh'),
                ),
            },
        )
    ],
)
- Off by default. With no
modelsmenu themodelargument is not in the tool schema at all, and every delegation runs exactly as it did before. - The keys are the interface. They are listed in the system prompt with each entry’s model and description, and the tool schema offers them as an enum, so the model picks from the menu instead of inventing a model name. Name them for the job (
'fast','deep'), not for the vendor. - An entry is a model or a
ModelOption.ModelOption(model, description=..., settings=...)adds a routing hint and per-optionModelSettings, so one key can mean “same model, more thinking”. Those settings merge over the sub-agent’s ownmodel_settings, which keeps the parts the option does not set. - Resolution order. The key the parent passed, else the delegate’s first allowed key (see below), else the delegate’s own model, else the parent run’s model.
- A delegate can be restricted.
SubAgent(linter, models=['fast'])pins that delegate tofast: the first listed key is what it runs on when the parent passes nomodel, and the others are refused with aModelRetry. The restriction is rendered in the prompt listing (- linter: Runs the linter (models: fast)). Restricting to a key the menu does not define is aValueErrorat construction. - A rejected key costs nothing. An unknown or unavailable key comes back as a
ModelRetrylisting the valid options, before the delegate’smax_callsbudget is charged.
Set workspace_resolver to offer delegate_task(working_directory=...). The async callback receives
the parent RunContext and a DelegationWorkspaceRequest with the delegate name and requested
directory, and returns a Workspace. The host
validates the request and decides which delegates may use another workspace. Without this option,
the tool omits working_directory and children inherit the parent’s workspace.
from pydantic_ai import Agent, RunContext
from pydantic_ai.exceptions import ModelRetry
from pydantic_ai.workspaces import LocalWorkspaceBackend, Workspace
from pydantic_ai_harness.filesystem import FileSystem
from pydantic_ai_harness.subagents import DelegationWorkspaceRequest, SubAgent, SubAgents

workspaces: dict[str, Workspace] = {'/repos/policy': Workspace(LocalWorkspaceBackend('/repos/policy'))}


async def resolve_workspace(ctx: RunContext[object], request: DelegationWorkspaceRequest) -> Workspace:
    if request.agent_name != 'reviewer' or request.directory not in workspaces:
        raise ModelRetry('Choose the reviewer and a configured directory.')
    return workspaces[request.directory]


reviewer = Agent(name='reviewer', deps_type=object, capabilities=[FileSystem(read_only=True)])
delegation = SubAgents(
    agents=[SubAgent(reviewer, read_only=True)],
    workspace_resolver=resolve_workspace,
)
The child runs with the returned workspace, so its relative file paths and repository instructions
use that directory. Read-only restrictions from the parent or SubAgent(read_only=True) still apply.
Also limit the delegate to trusted read-only tools: arbitrary Python tools can bypass the workspace
API. The resolver must preserve any additional backend restrictions the application requires.
The caller owns the returned workspace and keeps its resources alive until background children
finish. Managed tasks record the resolved directory in DelegationTask.working_directory. On resume,
omitting the argument resolves that saved directory again; changing it is rejected. The resolver must
therefore accept its own resolved directory spelling. Older tasks without this field inherit the
parent workspace. Remote and durable delegations reject directory overrides. This option does not
change where disk agent definitions are discovered: SubAgents.workspace controls that separately.
A soft outcome returns a steering message to the parent as a normal tool result, so its model reads the message and decides what to do next (rather than immediately re-delegating, which a ModelRetry invites). A timeout, a reached usage_limits budget, and an exhausted max_calls budget are always soft. When on_failure is set, the message it carries replaces the built-in default for these outcomes.
A sub-agent run that ends with DeferredToolRequests (its output_type includes it and a tool needed approval or was deferred) is a soft outcome too. The parent cannot approve the child’s tool calls or resume its run, and delegating the same task again would most likely stop the same way, so instead of returning the marker as output the delegation returns a steering message naming the sub-agent and why it stopped, or the on_failure message when that is set. A sub-agent that resolves its own deferred calls, for example with HandleDeferredToolCalls, never ends this way and returns its output as usual. A run that ends with PendingModelResponse (its output_type includes it and a model request was left waiting on the provider, for example in a batch) returns a steering message the same way, including on a remote worker, and the request is cancelled, since nobody will check on it later. Cancelling is best effort, and a batch is only cancelled once no other request in it is still waiting.
A sub-agent run that fails with a soft model error (ModelRetry, UnexpectedModelBehavior, e.g. it exhausted its own retries) is, by default, converted into a ModelRetry for the parent — so the parent’s model sees Sub-agent '<name>' failed: ... and can react by re-delegating. The delegate tool defaults to tool_retries=2, so the parent aborts only after that many consecutive delegate failures; the counter resets after any successful delegation. Raise tool_retries to tolerate a flakier sub-agent, or set None to inherit the parent agent’s default tool retries. Set on_failure for a delegate to make its failures soft instead: the child error returns the on_failure message as a normal tool result.
Hard errors propagate to stop the whole run. A UsageLimitExceeded from a child that has no per-delegate usage_limits (so it shares the parent’s accounting) means the whole tree is out of budget and propagates; a child reaching its own usage_limits is soft, as above.
An unexpected crash — any other exception the child raises, such as a provider ModelAPIError/FallbackExceptionGroup or a plain ValueError from a bad tool argument — propagates by default and aborts the parent run. Set contain_errors=True (per delegate, or as the SubAgents default) to catch it and return it to the parent as a bounded ModelRetry instead, so one delegate crash cannot kill the whole run. Containment stays loud: the exception rides the retry message (Sub-agent '<name>' crashed: ...), it is logged via the standard logging module, and tool_retries still bounds consecutive crashes into an abort. This is orthogonal to on_failure — a contained crash always raises the loud retry, never the soft on_failure return, so a genuine bug is never masked as success. Cancellation, a shared UsageLimitExceeded, pydantic-ai control-flow signals (CallDeferred, ApprovalRequired, the Skip* signals), and UserError bypass containment regardless of contain_errors. Cancellation covers both kinds: external cancellation (asyncio.CancelledError) propagates as-is, and a child’s own first-party cancellation (RunContext.cancel() inside the child, raising RunCancelled) leaves the delegate tool uncontained, after which pydantic-ai isolates it as a failed delegate_task return the parent model can react to, not a crash retry that invites re-delegation.
SubAgents emits typed capability events in the sub_agents namespace so a host can show a delegation as it runs, and how it ended, without parsing the delegate tool’s arguments and result:
| Event | Dispatch | When | Payload |
|---|---|---|---|
DelegationStartedEvent | stream | a delegation passed every check and the child run is about to start | agent_name, task, truncated, model (the menu key, or None), inherits_tools |
DelegationFinishedEvent | stream | the delegation settled into what the parent receives | agent_name, outcome, output, truncated, usage, duration_ms |
Both are notifications. One delegation is one delegate_task call, so a start and its end share the tool_call_id core stamps on every event; that is how a subscriber pairs them when the model delegates in parallel. duration_ms is in milliseconds. duration_seconds is its deprecated name: it still reads, in seconds and with a warning, and a payload saved under it still loads.
outcome follows the failure handling above: ok (the child’s output went back to the parent), timeout, budget (the child’s own usage_limits), failed (a soft model error, returned as on_failure or raised as a ModelRetry, or a child run that ended with DeferredToolRequests or PendingModelResponse, returned as a steering message), or contained (a crash contain_errors caught). output is what the delegate tool hands back to the parent in each case: the child’s output, the steering message, or the retry text. It is emitted from inside the tool, before any ToolGuardrail result guard screens that text for the model; a host that needs the screened version reads the ToolReturnPart in core’s FunctionToolResultEvent. usage is the child’s own RunUsage when it has separate accounting (usage_limits set, or forward_usage=False) and None when it accrues into the parent’s usage, where its share is not separable.
A delegation refused before the child runs (an unknown sub-agent, a model key off the menu, an exhausted max_calls budget) emits nothing; the tool result says why. An exception that propagates out of the delegate tool (a shared usage limit, an uncontained crash, a cancellation) ends without an end event. A SubAgentToolset registered directly in Agent(toolsets=[...]) has no owning capability and emits nothing. As with any capability event, a listener that raises aborts the parent run.
Their task and output are cut at MAX_EVENT_TEXT_CHARS (4096) with a truncated flag, so these two events cannot flood a persisted or forwarded event stream with one verbose delegation. The task events and AgentCreatedEvent are not cut.
from pydantic_ai import Agent
from pydantic_ai.capabilities import AbstractCapability, on_event
from pydantic_ai_harness.subagents import DelegationFinishedEvent, SubAgent, SubAgents


class ReportDelegations(AbstractCapability):
    @on_event(DelegationFinishedEvent)
    async def on_delegation_end(self, ctx, event: DelegationFinishedEvent) -> None:
        print(f'{event.agent_name}: {event.outcome} in {event.duration_ms / 1000:.1f}s')


researcher = Agent('anthropic:claude-opus-5-5', name='researcher')
agent = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[SubAgents(agents=[SubAgent(researcher)]), ReportDelegations()],
)
Nested model streaming from the child run is not an event concern; pass an event_stream_handler for that.
See capability events for how @on_event works.
SubAgents emits no OpenTelemetry spans for plain delegation: the child run is a core agent run with its own spans nested under the parent’s tool-call span, and the events above carry the outcome a trace would only show as an exception or a tool result.
Task control records its own decisions, which core’s spans don’t show, as zero-duration spans on the delegating run’s tracer, with sub_agents.-prefixed attributes, including sub_agents.agent_name (for a created agent, whose name the model chose, only as content) and, for a task, sub_agents.task_id:
| Span | When | Attributes |
|---|---|---|
sub_agents vetoed | a listener vetoed a task, message, answer, cancellation, or created agent | sub_agents.event (the vetoed event’s kind), sub_agents.veto_reason |
sub_agents task backgrounded | a task moved to the background | sub_agents.reason: requested, auto, or question |
sub_agents question answered | a listener answered a task’s question, not the model | sub_agents.question, sub_agents.answer |
sub_agents task refused | max_running_tasks refused a delegation | sub_agents.running_tasks, sub_agents.max_running_tasks |
sub_agents task not accepted | no worker picked a remote task up within accept_timeout | sub_agents.accept_timeout |
sub_agents remote task stopped | a remote task ended without its worker’s report, and its worker was told to stop it |
A veto reason, question, or answer, and the name a vetoed create_agent call asked for, are attached only when the run’s instrumentation includes content. While a top-level run waits for its background tasks, a sub_agents wait for tasks span covers the wait, with sub_agents.running_tasks.
By default a delegation finishes inside the delegate_task call that started it. With task_control=TaskControl(), delegations become tasks the model manages: they can run in the background, ask questions, be steered or cancelled, and be resumed.
from pydantic_ai import Agent
from pydantic_ai_harness import SubAgent, SubAgents
from pydantic_ai_harness.subagents import TaskControl

researcher = Agent('anthropic:claude-opus-5-5', name='researcher', description='Researches a topic and reports findings')

orchestrator = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[SubAgents(agents=[SubAgent(researcher)], task_control=TaskControl(auto_background_after=60))],
)
| Tool | Purpose |
|---|---|
delegate_task(agent_name, task, background=False, resume=None) | Start a task, or resume a finished one with its task ID. background=True returns a receipt right away. |
list_tasks() | The tasks this run started and the tasks they started, with status and IDs (the 50 most relevant). |
message_task(task_id, message) | Steer a running task; it reads the message, as sent, at its next model request. A task’s instructions tell it its delegating agent may send it messages. |
answer_task(task_id, answer) | Answer the question a task is waiting on. |
cancel_task(task_id, force=False) | Stop a task before its next model request, or right away with force=True, together with the tasks it started. |
- Reports and questions arrive as messages. A background task’s report is
<task_output>data, and a task’s question<task_question>data, on the user channel; the task-control instructions tell the model both are untrusted task data. A top-level run whose model ends while its background tasks still run waits for them, so their reports become its next request. - Questions. Each sub-agent gets an
ask_parent(question)tool. A question moves its task to the background, because the delegating model can only answer oncedelegate_taskreturns, and reaches that model as a message. Turn it off per delegate withSubAgent(can_ask_questions=False). A task that can’t run in the background (a run-owned workspace that isn’t local) gets noask_parent. - Limits.
TaskControl(auto_background_after=...)moves a task still running after that many seconds to the background.TaskControl(max_running_tasks=...)caps how many tasks a conversation runs at once, across its whole delegation tree.SubAgent(resumable=False)makes a delegate one-shot (see Managed delegation sessions forone_shot). All are off by default. - Who controls a task. Only the run that started a task can message, answer, or resume it. Any run above it can cancel it.
- Each run gets an owner. When no
DelegationTasksis bound,SubAgentsopens one for the run and cancels the tasks still running when the run ends. Delegations then follow the owner’s rules in Managed delegation sessions, including how a delegate’susage_limitsapply. Another agent’s run that one of the run’s tools starts is not a task, and doesn’t share the owner. Bind your own owner to keep tasks across runs, persist them, and observe them. - Only one
SubAgentson an agent can settask_control. The deprecated wrapper agents, such asTemporalAgent, give a run no durability capability, so the checks below can’t catch them; don’t use task control ordynamic_agentswith them. - On Temporal and DBOS, task control keeps the tasks in the workflow and runs each in a durable unit of its own, so recovery replays a background task’s events and reuses its result. On replay, a task sent to the background on request can get its
TaskBackgroundedEventafter it settles. A durable task can’t ask questions, take messages, or be resumed,cancel_taskstops it right away, and its report reaches the model when the run would otherwise end, not at its next request. On DBOS, a replayedlist_taskscan show a task’s status as of a different moment. Under durable execution, these raise aUserError:- task control with
include_self,remote_agentsorforward_events - task control with
auto_background_afterormax_running_tasksoutside Temporal - task control or
dynamic_agentson another durable engine, or within a boundDelegationTasksowner
- task control with
- On Temporal and DBOS,
dynamic_agentskeeps the roster in the workflow and runs each delegation other than toselfin a durable unit of its own, on the parent run’s model unless the created agent has one, so recovery rebuilds the created agents and reuses each delegation’s result. Thefactoryruns again on replay, so keep it deterministic. Engines that record each tool call in a unit of its own would lose the roster on replay, so they raise aUserError. Under any durability capability,SubAgentsneeds anid, which it has by default;id=Noneraises aUserError. - Task control and
DelegationTasksrun tasks as asyncio tasks, so they need the asyncio event loop: AnyIO’s Trio backend is not supported.
With task control, every step of a task is a typed capability event in the sub_agents namespace. A task’s events go into the event stream of the run that started it, so a nested task’s events reach its own parent’s run. A bound DelegationTasks observer also receives them as DelegationTaskEvent(event=...), including those of a task that settles after its delegating run ended. In place of TaskProgressEvent, it receives the task run’s own events, as it always did.
| Event | When | A listener can |
|---|---|---|
TaskAssignedEvent, TaskResumedEvent (TaskRequestEvent matches both) | a task is about to start, or to resume | rewrite prompt, or veto() it |
TaskStartedEvent | the task’s run is starting, locally or on a worker | |
TaskBackgroundedEvent | the task moved to the background; reason is requested, auto, or question | |
TaskProgressEvent | an event of the task’s own run, with TaskControl(forward_events=True) | |
TaskQuestionAskedEvent | the task asked a question | set answer, so the model is not asked |
TaskAnsweredEvent | an answer is about to reach the task | rewrite answer, or veto() it |
TaskSteeredEvent | a steering message is about to reach the task | rewrite message, or veto() it |
TaskCancelRequestedEvent, TaskForceCancelRequestedEvent | a cancellation is about to reach the task | veto() it |
TaskRetriedEvent | a worker is running a failed remote task again | |
TaskCompletedEvent, TaskFailedEvent, TaskCancelledEvent | the task settled | rewrite output of a completed task |
Unlike DelegationStartedEvent and DelegationFinishedEvent, these events are not cut at MAX_EVENT_TEXT_CHARS: each is the message itself, which a transport carries to the other side, so a prompt, question, answer, or output arrives whole. Nor is AgentCreatedEvent. A listener that persists or forwards them bounds them itself.
Events listeners can change are dispatched immediately, so their decisions take effect. A vetoed message is not sent, and the model is told why. With a bound DelegationTasks, DelegationStartedEvent and DelegationFinishedEvent go to its observer only, as in Managed delegation sessions; with the run’s own owner, they go to the run as before.
Earlier releases named some of these differently. The old class names still import, with a HarnessDeprecationWarning: SubAgentMessage, ParentMessage and ChildMessage (each now ends in Event), TaskFollowUpEvent (TaskResumedEvent), TaskMessageEvent (TaskSteeredEvent), TaskAnswerEvent (TaskAnsweredEvent), TaskCancelRequestEvent (TaskCancelRequestedEvent), TaskForceCancelEvent (TaskForceCancelRequestedEvent), TaskQuestionEvent (TaskQuestionAskedEvent) and TaskRetryEvent (TaskRetriedEvent). Each event’s kind is unchanged. AgentCreatedEvent.name is now agent_name, and parent_id on DelegationStartedEvent and DelegationFinishedEvent is now parent_task_id: the old attributes still read, with the same warning, and an event serialized under an old key still loads. Constructing one of these events takes the new keyword only. They serialize under the new keys: update code that reads a serialized event by key, and upgrade any process that loads events this release writes.
from pydantic_ai.capabilities import AbstractCapability, on_event
from pydantic_ai_harness.subagents import TaskAssignedEvent, TaskQuestionAskedEvent


class DelegationPolicy(AbstractCapability):
    @on_event(TaskAssignedEvent)
    async def check_task(self, ctx, event: TaskAssignedEvent) -> None:
        if 'production' in event.prompt:
            event.veto('ask the user before touching production')

    @on_event(TaskQuestionAskedEvent)
    async def answer_known(self, ctx, event: TaskQuestionAskedEvent) -> None:
        if event.question == 'Which branch?':
            event.answer = 'main'
A SubAgentWorker serves agents to delegating agents in other processes. The delegating side lists them as RemoteSubAgents, by name, and reaches them through a SubAgentTransport:
from pydantic_ai import Agent
from pydantic_ai_harness.subagents import RemoteSubAgent, SubAgents, SubAgentWorker, TaskControl

transport = ...  # a SubAgentTransport both processes reach


# In the process that hosts the agent:
async def serve():
    researcher = Agent('anthropic:claude-opus-5-5', name='researcher')
    await SubAgentWorker(agents={'researcher': researcher}, transport=transport, deps=None).serve()


# In the delegating process:
orchestrator = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[
        SubAgents(
            task_control=TaskControl(
                remote_agents=[RemoteSubAgent(name='researcher', description='Researches a topic')],
                transport=transport,
            )
        )
    ],
)
- A transport is a set of mailboxes. Implement
send,receive, and optionallyreleaseover a WebSocket, a Redis list, or anything else that moves bytes, usingserialize_messageanddeserialize_messageat the boundary. Every message is one of theSubAgentMessageEvents above.InMemoryTransportserves a worker in the same process. - The transport is the trust boundary. Anyone who can send to it can run the served agents, with their tools and
deps, and read what they return. Put authentication, authorization, and network binding in your transport. A worker’s output and errors reach the delegating model like a local delegate’s: in the foreground as tool results, in the background as framed reports. - A transport reports a lost worker. A worker that stops sends
TaskFailedEventfor the tasks it was running. One that dies without doing so can’t: the delegating run then waits for its report until the run is cancelled, unlessreceiveraises when the worker is gone. Heartbeats are not part of the protocol. - The worker runs the agent with its own model, tools, and
deps, which never cross the transport. It takes the agents it serves by name, without per-delegate run controls: those belong to the delegating side’sSubAgents. It applies the delegating run’s usage limits to the task’s own usage, and continues the delegating run’s trace. The usage it reports with the settled event is added to the delegating run’s usage, unlessforward_usage=False. - A task nobody picks up fails. The worker sends
TaskStartedEventwhen it starts a task. A remote task that no worker picks up withinTaskControl.accept_timeoutseconds (default30) fails, and a remote task that stops without its worker’s report, for example because its delegating run ended, is force-cancelled on the worker. SubAgentWorker(retries=...)runs a failed task again from its prompt, with aTaskRetriedEvent. The worker keeps up tomax_conversationstask conversations (default1000) so they can be resumed. The conversation stays in that worker, so serve each remote agent name from one worker: a follow-up that reaches another worker fails, since it has no conversation to resume.- A remote agent runs on its worker’s model, so
delegate_taskrefuses amodelfor it, and its delegations emit noDelegationStartedEventorDelegationFinishedEvent.
With dynamic_agents, the model gets a create_agent(name, description, instructions, model=None) tool and can delegate to the agents it creates until the run ends. This works with or without task control.
from pydantic_ai_harness.subagents import DynamicAgents, SubAgents

SubAgents(models={'fast': 'anthropic:claude-haiku-5-5'}, dynamic_agents=DynamicAgents(models=['fast'], max_agents=3))
- A created agent is an
Agentwith the model-written instructions and no tools, on themodelskey it was created with, or on the delegating run’s model whenDynamicAgents.modelsis empty. It has nonameordescriptionof its own, since tracing records those even without content. The model delegates to it by the name it gave increate_agent. The description goes only to a custom factory, asDynamicAgentSpec.description, and is never shown to the model: created agents aren’t added to the cache-stable roster. PassDynamicAgents(factory=...)to build it yourself from theDynamicAgentSpec. - An
AgentCreatedEventis dispatched immediately before the agent is created: a listener can rewrite itsinstructions(and itsdescription, which only a custom factory reads), orveto()it. max_agents(default5) caps how many agents one run creates. Only oneSubAgentson an agent can setdynamic_agents.
Task control, remote agents, and created agents are a port of subagents-pydantic-ai, a community package by Vstorm (MIT licensed).
SubAgents delegates in the foreground only, unless a caller opens and binds a DelegationTasks
owner. The owner adds background and resume to the delegate tool’s schema, gives every child a
stable conversation ID, and owns every worker, an asyncio task, until shutdown. No extra agent loop
is implemented.
Use DelegationReports on the parent run to deliver settled background reports through core’s
queued-message API. Each report is the child’s output in a UserPromptPart, framed as
<task_output task_id="..." agent_name="..."> data, with outcome="..." added when the task
didn’t succeed, like a background tool’s <pyai:tool_result>. The output was written by a model, so it
never enters system voice, and a closing tag inside it can’t end the frame early. Nothing precedes
the frame: the acceptance receipt the parent got at launch already said a report would follow.
Reports default to priority='when_idle' so active parents finish their current work first. A host
that starts an idle continuation should use DelegationReports(..., priority='asap') and
agent.run(None, ...): pending reports then enter the first model request, with no synthetic user
prompt. The host owns wake-up scheduling between runs. A report or question that arrives after a
run has read its last queued messages is kept for the conversation’s next run.
Use is_task_report(part) to recognize the output part, or a task’s question, which arrives the
same way framed as <task_question task_id="..." agent_name="...">, for example to keep it out of
a transcript of what the user typed. Like BackgroundTools completions, the metadata is never sent
to the model, but the Vercel AI and AG-UI message conversions omit it: a history that round-trips
through them returns the report or question as plain user text, and is_task_report no longer
matches it. History passed in message_history is trusted as the caller’s own, this metadata
included. Load history from an untrusted client with a UI adapter, which never puts client metadata
on message content, or pass it through sanitize_messages, which resets TextContent.metadata.
from pathlib import Path

from pydantic_ai import Agent
from pydantic_ai_harness.subagents import DelegationReports, DelegationTasks, SubAgents

agent = Agent('anthropic:claude-sonnet-5-5', capabilities=[SubAgents(include_self=True)])
tasks = DelegationTasks(directory=Path('.task-history'))

async def converse():
    async with tasks.opened():
        with tasks.bind():
            result = await agent.run(
                'Delegate an independent investigation in the background.',
                conversation_id='review',
                capabilities=[DelegationReports(tasks, conversation_id='review')],
            )
            print(result.output)
            # Keep this owner open across subsequent parent turns.
opened() drains workers on exit. A task still running when its process exited is
loaded as cancelled when the owner next opens; if it was waiting for an answer, its output
names the question, so the parent can resume it with the answer. Keep workspace and plugin
resources alive outside that scope. Detached execution is refused for run-owned non-local workspaces;
foreground delegation still works. max_depth=4 counts the main run and allows
three child layers. An explicitly configured non-default SubAgents.max_depth
still takes precedence. Ordinary SubAgents retains its original depth default.
restore(task) adds a finished DelegationTask made elsewhere, such as one imported
from another agent’s session, so the parent can resume it by ID. It works before
opened() too; the owner loads the task when it opens. A task with the same ID that
has run since, under a different run_id, is kept rather than replaced, and
restore returns False.
background(task_id) releases a foreground waiter without restarting the child.
await cancel(task_id) stops and drains that child and its descendants. A user stop
blocks model-requested resume until the application explicitly calls
await allow_resume(task_id). one_shot names never resume. SubAgent(resumable=False)
does the same for one delegate, also with the owner SubAgents(task_control=...) opens: use
one_shot when the application binds the owner and decides by agent name, and resumable
where the delegate is declared. Either one makes the task one-shot. A resume uses the same
child ID and its independent history, a new run ID, and the current direct parent.
A child waits for its own descendants and consumes their reports before its final
output settles. Reports are routed to the direct parent; an idle parent receives
pending reports on its next explicitly started run. Enqueue delivery is acknowledged
only when core emits EnqueuedMessagesEvent, and acknowledgements are persisted.
With task control, a child’s ask_parent question is routed the same way:
questions(conversation_id=...) lists the children whose question awaits delivery, and
the observer is notified when one starts waiting, so an application can start its idle
parent’s next run to answer it.
steer(task_id, text) sends a running child a user message on its own run’s queue
with priority='asap': the child reads it at its next model request, and one about to
finish goes on with it instead. It returns False when the child is not running, so an
application can offer to resume it. A message sent before the child’s run starts waits
for it; one sent as the child’s final response settles may arrive too late for it to read.
An observer receives DelegationTaskEvent, with the task identity and an optional
correlated child stream event. Events from the child’s own stream also carry the
model_name and context_window of the model streaming that request, so a UI can
show the child’s context usage. Managed start/end events carry task_id and
parent_task_id. Managed cancellation and uncontained exceptions produce terminal
outcomes; unmanaged events and exception propagation keep their original contract.
Metadata and final/interrupted histories are atomically saved under directory.
Pass step_store to checkpoint through StepPersistence and recover a process-killed
child’s latest frontier. Loading an interrupted record never executes its tools.
Inspect possible partial effects before an explicit resume. A resume closes out tool
calls the interruption left unanswered with an interrupted tool return, so the child
sees they did not complete.
Each saved file loads on its own. A file that cannot be read or validated, whose name
does not match its task ID, or whose saved ancestry loops is skipped and left on disk:
opened() logs a warning and lists it in problems as a SavedTaskProblem (its path
and the reason), and the other tasks still load. To list a saved task tree without
opening an owner or resuming anything, for example from a dashboard or another process,
call DelegationTasks.discover(directory). It returns SavedTasks, with the loaded
tasks by ID (follow parent_id for the tree) and the same problems. discover()
writes nothing, and returns a task saved as running unchanged, since the process that
owns it may still be running it.
from pathlib import Path

from pydantic_ai_harness.subagents import DelegationTasks


async def show_saved_tasks():
    saved = await DelegationTasks.discover(Path('.task-history'))
    for task in saved.tasks.values():
        print(task.id, task.parent_id, task.agent_name, task.status, task.outcome)
    for problem in saved.problems:
        print(f'Skipped {problem.path}: {problem.reason}')
Managed children with forward_usage=True share live usage accounting and inherit
parent ceilings. A per-child budget is converted to an absolute ceiling at launch;
concurrent sibling spend may reach that ceiling earlier, but cannot bypass the
parent’s budget. The ordinary unmanaged per-child accounting contract is unchanged.
agents, aliases, and instructions extend the roster and guidance only inside
the bound scope; they do not add delegation to an agent without SubAgents.
SubAgent(read_only=True) wraps the child’s workspace in ReadOnlyWorkspace.
Also give that agent only trusted read-only capabilities: arbitrary Python tools
can bypass the workspace API. CLAI’s Explore and Plan specialists use filesystem
readers and expose no shell, code execution, or parent plugin tools.
Core’s agent/model/tool spans provide execution telemetry; task IDs, parent IDs, and child run IDs provide correlation. This owner adds no logging exporter.
By default, on Temporal a delegation to an agent other than self runs in an activity, and on DBOS it runs inline in the parent workflow, so a delegate’s own durability does nothing. To keep it, run the delegate tool as a child workflow (Temporal, DBOS) with SetToolMetadata:
from pydantic_ai import Agent
from pydantic_ai.capabilities import SetToolMetadata
from pydantic_ai.durable_exec.temporal import TemporalDurability
from pydantic_ai_harness.subagents import SubAgent, SubAgents

worker = Agent('anthropic:claude-opus-5-5', name='worker', capabilities=[TemporalDurability()])

lead = Agent(
    'anthropic:claude-opus-5-5',
    name='lead',
    capabilities=[
        SubAgents(agents=[SubAgent(worker)]),
        SetToolMetadata(tools=['delegate_task'], temporal={'child_workflow': {}}),
        TemporalDurability(),
    ],
)
On DBOS, use DBOSDurability() and SetToolMetadata(tools=['delegate_task'], dbos={'child_workflow': {}}). The delegate’s model requests and tool calls are then recorded in the child’s history rather than the parent’s.
- Every delegate must be durable on the parent’s engine: the tool body runs as workflow code.
- On Temporal, register each delegate with the worker too, for example with an
AgentPlugin. include_self,inherit_tools,models,shared_capabilities,event_stream_handler,dynamic_agents,task_control, and a delegate’smax_callsrely on parent-run state the child workflow doesn’t receive, so a delegation with any of them raises aUserError.- The delegate’s usage isn’t reliably counted in the parent run’s usage, and the parent’s usage limits don’t bound it.
- The delegation depth isn’t carried into the child workflow, so if a delegate’s own
SubAgentsalso opts in,max_depthcounts again from each child workflow and no longer bounds the tree.
The sub-agents are listed in the system prompt via get_instructions, using each agent’s description (or a SubAgent(description=...) override). A sub-agent with no description is listed by name alone.
A repo’s agent definitions can become delegates without writing any Agent code. With agent_folders set, every Claude-style *.md file and Codex-style *.toml file under those folders is loaded as a sub-agent, alongside the explicitly-passed agents. Files are read in sorted filename order.
from pydantic_ai import Agent
from pydantic_ai_harness import SubAgents

orchestrator = Agent(
    'anthropic:claude-opus-5-5',
    capabilities=[SubAgents(agent_folders='agents')],  # loads .agents/agents/ from the run's workspace
)
Definitions are read at the start of every run from the run’s workspace, so a sandbox’s agent files are found and nothing is read from your home directory. To read them from somewhere else, such as definitions that ship with your application, pass workspace=LocalWorkspaceBackend('/app').
agent_folders controls which folders are read:
- A folder-name
str('agents'is the conventional layout): load from.agents/<name>/,.claude/<name>/, and.codex/<name>/under the workspace’s working directory, in that order, so a workspace that uses.agents/for something else (such as skills) still loads agents from the others. A run without a workspace skips them. - A sequence of workspace paths, absolute or relative to the working directory, loads from exactly those folders, in order.
None, the default, disables disk loading, exposing only the explicitly-passedagents.
Folders are read only through a workspace. A run without a workspace fails at its start when given a path sequence. Convention discovery warns once when it skips a .agents/ or .claude/ folder in the current or home directory that the workspace does not reach, naming the folder and the workspace= that reads it.
A definition is a Claude-style markdown file with optional frontmatter, or a Codex-style TOML file. Markdown:
---
name: researcher
description: Researches a topic and reports findings
tools: Read, Grep
---
You research topics. Report your findings, each with a source.
nameis the delegate name (how the parent refers to it and how it is listed). It falls back to the filename stem when absent.descriptiondrives the prompt listing.- The markdown body becomes the agent’s instructions.
tools(orallowed-tools) is a comma-separated string or a YAML block list. See “Tools” below.modelandcolorare ignored: the model is inherited from the parent (see below), andcolorhas no pyai equivalent.
Frontmatter is read by a small, dependency-free parser limited to those keys (pyyaml is not a harness dependency). Full YAML frontmatter is not supported.
A Codex-style standalone TOML file:
name = "reviewer"
description = "Reviews code for bugs"
developer_instructions = "Inspect the code and report findings. Do not edit files."
tools = ["Read", "Grep"]
name,description, anddeveloper_instructionsare required nonempty strings.tools(orallowed-tools) is optional: a list of strings or a comma-separated string, not both keys.model,effort,model_reasoning_effort, andcolorare ignored with a warning; useagent_overridesfor models and effort.- Any other key, including sandbox or permission settings, skips that file with a warning rather than silently granting broader tools. The older
[agents.<name>] config_filelayout is not supported. - TOML files are parsed with the standard-library
tomllibmodule.
Nothing in a definition file is executed. A malformed or invalid file is skipped with a warning without blocking the others.
Disk agents inherit the parent run’s model by default. Per agent, the caller can override the model and set a thinking/effort level via agent_overrides, keyed by the agent’s name:
from pydantic_ai_harness import SubAgents
from pydantic_ai_harness.subagents import AgentOverride

SubAgents(
    agent_folders='agents',
    agent_overrides={'researcher': AgentOverride(model='anthropic:claude-opus-5-5', effort='high')},
)
When effort is unset, the disk agent adds no thinking setting, so the inherited model’s defaults apply. An explicit value, including False or 'minimal', is passed through unchanged via Pydantic AI’s ModelSettings.thinking.
MINIMUM_EFFORT_FLOOR and clamp_effort(level, floor=...) remain importable for compatibility but are deprecated. SubAgents no longer uses them. Pass AgentOverride(effort=...) when a disk agent needs an explicit level, or apply an application-specific floor outside the capability.
Without a tool_resolver, a disk agent gets no tools and its tools frontmatter is ignored. To map the frontmatter tool names to toolsets, pass a tool_resolver: it receives each tool name (so it can honor entries like Bash(git:*)) and returns the toolsets that provide it, or None for an unknown name, which is skipped with a warning.
from collections.abc import Sequence

from pydantic_ai.toolsets import AgentToolset
from pydantic_ai_harness import SubAgents

TOOLSETS: dict[str, Sequence[AgentToolset[object]]] = {}  # your tool name -> toolsets mapping


def resolve(tool_name: str) -> Sequence[AgentToolset[object]] | None:
    return TOOLSETS.get(tool_name)

SubAgents(agent_folders='agents', tool_resolver=resolve)
When the same name appears in more than one source, the higher-precedence one wins and the others are skipped with a warning: explicitly-passed agents first; for convention discovery, the workspace’s .agents/ folder, then .claude/, then .codex/; and for an explicit path sequence, earlier folders before later ones. A duplicate name within the explicitly-passed agents list is still an error.
from pydantic_ai_harness import SubAgents

SubAgents(
    agents=(),             # Sequence[SubAgent[AgentDepsT]] -- each pairs an agent with its run controls
    models={},             # Mapping[str, Model | str | ModelOption] -- per-delegation model menu (off when empty)
    agent_folders=None,    # folder-name str ('agents' is conventional) | Sequence[str | Path] workspace paths | None
    agent_overrides={},    # Mapping[str, AgentOverride] -- per-disk-agent model/effort override
    tool_resolver=None,    # Callable[[str], Sequence[AgentToolset[object]] | None] -- disk-agent tool mapping
    forward_usage=True,    # share the parent's usage with sub-agent runs
    inherit_tools=False,   # deprecated: use include_self=True, or tool_resolver for disk agents
    shared_capabilities=(),# capabilities applied to every sub-agent run
    event_stream_handler=None,  # forwarded to each sub-agent run to stream its events
    tool_name='delegate_task',
    tool_retries=2,        # extra delegate-tool attempts after a sub-agent error before aborting (None inherits the agent default)
    contain_errors=False,  # default for SubAgent.contain_errors: contain an unexpected crash as a bounded retry
    workspace=None,        # WorkspaceBackend to read agent_folders from instead of the run's workspace
    workspace_resolver=None,  # async (ctx, request: DelegationWorkspaceRequest) -> Workspace
    include_self=False,    # also list the running agent itself as the delegate `self`
    max_depth=3,           # delegation levels, counting the top-level run
    task_control=None,     # TaskControl -- background tasks, task-control tools, questions, and task events
    dynamic_agents=None,   # DynamicAgents -- let the model create sub-agents with `create_agent`
)
from pydantic_ai import Agent
from pydantic_ai_harness import SubAgent

agent = Agent('anthropic:claude-opus-5-5')

SubAgent(
    agent,                 # AbstractAgent[AgentDepsT, Any] -- the child agent to run
    name=None,             # delegate name; defaults to the agent's own `name`
    description=None,      # prompt-listing description; defaults to the agent's own `description`
    models=None,           # Sequence[str] -- menu keys this delegate may run on; the first is its default
    usage_limits=None,     # per-delegation request/token budget (isolated accounting)
    timeout_seconds=None,  # per-delegation wall-clock budget
    max_calls=None,        # max delegations to this sub-agent per parent run
    on_failure=None,       # steering message for soft degradations of this delegate
    contain_errors=None,   # contain an unexpected crash as a bounded retry; None inherits the SubAgents default
    resumable=True,        # whether a finished task can be resumed, with a task owner
    can_ask_questions=True,  # give the sub-agent `ask_parent`, with task_control
)
from pydantic_ai_harness.subagents import TaskControl

TaskControl(
    remote_agents=(),      # Sequence[RemoteSubAgent] -- agents a SubAgentWorker serves
    transport=None,        # SubAgentTransport reaching that worker, required with remote_agents
    accept_timeout=30.0,   # seconds a remote task waits for a worker to pick it up
    auto_background_after=None,  # seconds a delegation waits before its task moves to the background
    max_running_tasks=None,      # tasks a conversation may run at once, across its delegation tree
    forward_events=False,  # forward the events of task runs as TaskProgressEvent
)
SubAgents is not serializable via the agent spec (it holds live Agent instances), so get_serialization_name() returns None.
- Sub-agents can themselves have
SubAgents, forming a tree. EachSubAgentsstops offering delegation once the run is at its ownmax_depth, so a delegate with a higher limit can go deeper than its parent’s. Shareusage(the default) and set ausage_limitson the top-level run to bound the whole tree. - Delegations the model issues in parallel run as independent sub-agent runs.
Bases: AbstractCapability[AgentDepsT]
Let an agent delegate self-contained tasks to named sub-agents.
Exposes a single delegate_task(agent_name, task) tool. Each delegation runs the chosen
sub-agent in a fresh run that does not see the parent conversation. The available sub-agents
are listed in the system prompt; a change to the listing between runs of a conversation is
appended rather than rewritten.
Delegates come from agents, from Markdown or TOML definitions under agent_folders, and,
with include_self=True, from the running agent itself. With a models menu, delegate_task
also takes a model argument naming one of its keys. The parent’s deps are forwarded to
each sub-agent, and delegations nest at most max_depth levels.
from pydantic_ai import Agent
from pydantic_ai_harness.subagents import SubAgent, SubAgents

researcher = Agent('anthropic:claude-sonnet-4-6', name='researcher', description='Researches topics')
writer = Agent('anthropic:claude-sonnet-4-6', name='writer', description='Writes prose')

orchestrator = Agent(
    'anthropic:claude-opus-4-7',
    capabilities=[SubAgents(agents=[SubAgent(researcher), SubAgent(writer)])],
)
The sub-agents to expose, each a SubAgent pairing an agent with its
per-delegate run controls. See SubAgent. These take precedence over any
disk-loaded agents of the same name.
Type: Sequence[SubAgent[AgentDepsT]] Default: ()
A menu of models the parent can route an individual delegation to, keyed by
the name the parent uses to pick one. Off by default: with no menu the delegate
tool has no model argument and every delegation runs the way it always did.
Each value is a model reference, or a ModelOption carrying a routing hint and
its own ModelSettings (so one key can mean “same model, more thinking”). The
keys and their descriptions are listed in the system prompt, so name them for
the job — 'fast', 'deep' — rather than for the vendor. SubAgent.models
restricts which of them a given delegate accepts.
from pydantic_ai_harness.subagents import SubAgents

SubAgents(models={'fast': 'anthropic:claude-haiku-4-5', 'deep': 'anthropic:claude-opus-4-7'})
Type: Mapping[str, Model | KnownModelName | str | ModelOption] Default: field(default_factory=(dict[str, 'Model | KnownModelName | str | ModelOption']))
Where to load Markdown and standalone Codex TOML definitions from, in addition to agents.
Off by default: only agents are exposed unless this is set. Every folder is
read at the start of each run through the run’s workspace (ctx.workspace),
or through workspace when set.
- a folder-name
str('agents'is the conventional layout): load from.agents/<name>/,.claude/<name>/, and.codex/<name>/under the workspace’s working directory, in that order. Skipped when the run has no workspace. - a sequence of paths in the workspace, absolute or relative to its working
directory: load from exactly those folders, in order. A run with no workspace
fails at its start; pass
workspace=LocalWorkspaceBackend('.')to read them from this machine. None: no disk loading (the default).
Missing folders are skipped. Within a folder every *.md and *.toml file is a candidate.
Type: str | Sequence[str | Path] | None Default: None
Per-disk-agent overrides keyed by the agent’s name. An entry can set the
agent’s model (otherwise the parent’s model is inherited) and its effort
(otherwise no thinking setting is added). Has no effect on explicitly-passed agents.
Type: Mapping[str, AgentOverride] Default: field(default_factory=(dict[str, AgentOverride]))
Optional override for how a disk agent gets its tools. When set, each tool
name in a definition’s tools/allowed-tools frontmatter is passed to this
resolver and the returned toolsets are attached to that agent; an unknown name
(resolver returns None) is skipped with a warning. When unset, the
frontmatter tool list is ignored and disk agents have no tools of their own.
Type: ToolResolver | None Default: None
If True, the parent run’s usage is shared with each sub-agent run, so
token usage aggregates and usage limits apply across the whole agent tree.
Type: bool Default: True
Deprecated: setting it to True emits a HarnessDeprecationWarning.
If True, the parent agent’s own tools (registered via tools= or toolsets=,
not those contributed by capabilities) are exposed to each sub-agent run, minus
the delegate tool. Bind required tools directly to explicit sub-agents, use
include_self=True to delegate to an agent with all of the parent’s tools and
capabilities, or use tool_resolver to give disk agents tools.
Type: bool Default: False
Capabilities applied to every sub-agent run, in addition to whatever each sub-agent already has.
Type: Sequence[AgentCapability[AgentDepsT]] Default: ()
If set, this handler is passed to each sub-agent run, so the sub-agent’s
model-streaming and tool events surface to the caller. The handler receives
the sub-agent’s own RunContext and event stream.
Type: EventStreamHandler[AgentDepsT] | None Default: None
Name of the delegate tool exposed to the model.
Type: str Default: 'delegate_task'
Fixed, since an agent exposes a single delegate tool. Durable execution requires one.
Two SubAgents capabilities would register the same tool_name and collide. The shared id
makes them merge instead, unioning their rosters, so a packaged harness that delegates can
compose with another that does the same.
Type: str | None Default: field(default='sub_agents', kw_only=True)
Retries for the delegate tool — how many extra attempts it gets after a
sub-agent error before the parent run aborts. A sub-agent failure (e.g. it
exhausts its own output retries) surfaces to the parent as a tool retry it
can react to by re-delegating with a corrected task. The retry counter
resets after any successful delegation, so this bounds consecutive failures,
not total ones. Defaults to 2 (pydantic-ai’s per-tool default is 1) so a
repeated flaky sub-agent does not abort the parent run on its first repeat;
set None to inherit the parent agent’s default tool retries instead.
Default for SubAgent.contain_errors: whether an unexpected sub-agent crash
is caught and returned to the parent as a bounded ModelRetry instead of
aborting the parent run. Off by default, so a crash propagates. Any SubAgent
can override this per delegate. See SubAgent.contain_errors for the
containment contract and what always propagates regardless.
Type: bool Default: False
A workspace to read agent_folders from instead of the run’s, such as
LocalWorkspaceBackend('/app') for definitions that ship with the application.
A backend, not the LocalWorkspace capability. It is used in-process only: a durable engine
does not route it through its workflow machinery.
Type: WorkspaceBackend | None Default: field(default=None, kw_only=True)
Opt into delegate_task(working_directory=...) with an async callback receiving the parent
context and a DelegationWorkspaceRequest with the delegate name and requested directory.
Return the child’s Workspace; the caller owns
its resources, including keeping it alive for background tasks. Omission keeps the parent workspace.
The callback validates paths and decides which delegates and backends may change directory.
Parent and delegate read-only restrictions still apply. Tools that bypass the workspace API need
their own restrictions. Remote and durable delegations cannot request another directory.
Resuming a task keeps its saved directory; the resolver is called again for that directory.
This does not change where agent_folders are discovered (see workspace).
Type: WorkspaceResolver[AgentDepsT] | None Default: field(default=None, kw_only=True)
If True, the roster also lists the running agent itself, as self.
A delegation to self starts a fresh run of RunContext.agent on the parent run’s model
(or the models option the parent picks), so the delegate has every capability, toolset, and instruction bound to that Agent —
guardrails, approval gates, and audit hooks included, since they are registered again in
the child run. What was passed to the parent’s run() rather than bound to the Agent
(run-level capabilities, toolsets, instructions, model_settings) does not carry
over, so this capability has to be bound to the Agent itself; passing it to run()
raises a UserError when the run starts.
inherit_tools does not apply to self, whose tools are already the parent’s. The
delegate can delegate in turn, up to max_depth.
Type: bool Default: False
How many levels a delegation tree may have, counting the top-level run as the first.
The default of 3 lets the top-level run delegate, and its delegates delegate once more.
A run at the limit gets neither the delegate tool nor the sub-agent listing. The level
is tracked per task tree, across every SubAgents capability, and each capability enforces
its own limit. This bounds include_self, whose delegate carries the delegate tool again,
and a roster that reaches the same agent through another path.
Type: int Default: DEFAULT_MAX_DEPTH
Let delegations outlive the tool call, and give the model tools to manage them. Off by default.
See TaskControl. Only one SubAgents on an agent can set it. On Temporal and DBOS, each task runs in a durable
unit of its own, which can’t ask questions, take messages, or be resumed. Under durable execution, include_self,
remote_agents, forward_events, auto_background_after or max_running_tasks outside Temporal, other durable
engines, and a bound DelegationTasks owner raise a UserError.
Type: TaskControl | None Default: field(default=None, kw_only=True)
Let the model create sub-agents during a run, with a create_agent tool. Off by default.
Only one SubAgents on an agent can set it. On Temporal and DBOS, every delegation other than to self runs in a
durable unit of its own, so recovery rebuilds the created agents and reuses the delegations’ results. Other durable
engines, and a bound DelegationTasks owner under any of them, raise a UserError.
Type: DynamicAgents[AgentDepsT] | None Default: field(default=None, kw_only=True)
@async
def for_run(ctx: RunContext[AgentDepsT]) -> SubAgents[AgentDepsT]
A per-run copy when agent folders are read; otherwise self.
A run at max_depth gets a copy without the delegate tool and listing instead. The per-run
copy starts from the explicit roster; before_run adds the folders’ definitions. Its
instructions and toolset are read after that, so they list the delegates this run has.
SubAgents[AgentDepsT]
@async
def before_run(ctx: RunContext[AgentDepsT]) -> None
Read the agent folders’ definitions through the workspace and rebuild this run’s roster.
@async
def wrap_run(
    ctx: RunContext[AgentDepsT],
    *,
    handler: WrapRunHandler,
) -> AgentRunResult[Any]
Run the parent agent, then drop this run’s delegation counts so they don’t accumulate.
With task_control set, the run gets a DelegationTasks owner unless the application bound one, and
the task events of its children are published into its event stream.
@async
def after_output_process(
    ctx: RunContext[AgentDepsT],
    *,
    output_context: OutputContext,
    output: Any,
) -> Any
Keep a top-level run with its own owner going while its background tasks work.
The run waits until they settle, or one asks a question, and their reports become its next request.
def get_instructions() -> AgentInstructions[AgentDepsT] | None
Cache-stable listing of the available sub-agents and models.
A per-run copy returns it as a function, rendered after before_run has read the
workspace’s definitions; it is the same text on every step of the run.
AgentInstructions[AgentDepsT] | None
def get_toolset() -> AgentToolset[AgentDepsT] | None
Toolset providing the delegate tool, or None when no sub-agents are configured.
A per-run copy returns a function yielding the toolset before_run settled on, the same
instance for every step of the run.
AgentToolset[AgentDepsT] | None
@classmethod
def get_serialization_name(cls) -> str | None
Not spec-serializable — the capability holds live Agent instances.
@classmethod
def combine(
    cls,
    capabilities: Sequence[AbstractCapability[AgentDepsT]],
) -> AbstractCapability[AgentDepsT]
Compose the rosters, and require everything else to already agree.
Two packaged harnesses on one agent each bring their delegates, and composing them is what
the shared id is for. Only agents, models, and include_self are composed. Every other
field decides how the delegates run — what capabilities they are handed, whether they see the parent’s
tools, what the delegate tool is called, where delegates are loaded from — so merging it
would apply one harness’s policy to the other’s sub-agents, which neither author asked for.
Those must agree, and say so when they do not.
Disk definitions are not part of the merge: the per-run copy reads them in before_run,
after run-level capabilities are combined.
AbstractCapability[AgentDepsT]
Bases: Generic[AgentDepsT]
One delegate: a child agent plus its per-delegate run controls.
Pass a sequence of these as SubAgents(agents=[...]). The delegate’s name —
how the parent model refers to it, and how it is listed in the system prompt —
is name when set, otherwise the agent’s own name. An agent with neither is
rejected by SubAgents.
Every control below is optional; an unset field leaves the corresponding
behaviour at the SubAgents default.
The agent that runs when this delegate is invoked.
Type: AbstractAgent[AgentDepsT, Any]
Name the parent model uses to delegate to this agent. Defaults to the
agent’s own name when unset.
Type: str | None Default: None
Description for the system-prompt listing. Defaults to the agent’s own
description when unset; a delegate with neither is listed by name alone.
Type: str | None Default: None
Which of SubAgents.models this delegate may run on, as menu keys, and
which one it runs on by default: the first key listed. Leave it unset to let
the parent pick any configured option and to fall back to the delegate’s own
model when it picks none. Set it to pin a delegate to one option
(models=['fast']) or to bound an expensive delegate to a subset. Naming a key
the menu does not define is an error.
Type: Sequence[str] | None Default: None
Request/token budget for one delegation. When set, the child runs with
its own usage accounting so the budget counts only the child’s own requests
and tokens (not the parent’s or siblings’). When forward_usage=True, that
usage is added to the parent’s usage after the delegation. Hitting this budget
is a soft outcome (steering message), not a run-stopping UsageLimitExceeded.
Type: UsageLimits | None Default: None
Wall-clock budget for one delegation. When the child exceeds it, the run is cancelled and the parent gets a soft steering message instead of hanging on the child.
Type: float | None Default: None
Maximum number of delegations to this sub-agent per parent run. Once reached, further delegations return a soft budget-exhausted message without running the child.
Type: int | None Default: None
Steering message returned to the parent for any soft degradation of this
delegate (timeout, child failure, a child run ending with DeferredToolRequests or PendingModelResponse,
usage budget reached, call budget exhausted), in place of the built-in default. Setting it also makes child
failures soft: a child error returns this message as a normal tool result
instead of raising a parent ModelRetry.
Type: str | None Default: None
Whether an unexpected sub-agent crash is contained instead of aborting the
parent run. When True, an exception the child raises that is not an expected
soft degradation (a provider ModelAPIError/FallbackExceptionGroup, a plain
ValueError from a bad tool argument, etc.) is caught and returned to the parent
as a bounded ModelRetry, so one delegate crash cannot kill the whole run. It
stays loud: the exception rides the retry message and is logged, and
tool_retries still bounds consecutive crashes into an abort. Cancellation, a
shared usage-limit, pydantic-ai control-flow signals, and UserError always
propagate regardless. Unset inherits SubAgents.contain_errors (default off).
Orthogonal to on_failure, which only sets the message for expected soft
degradations; a contained crash always raises the loud ModelRetry.
Type: bool | None Default: None
Run in a ReadOnlyWorkspace; supply only trusted read-only tools as well.
Type: bool Default: dataclass_field(default=False, kw_only=True)
Whether a finished task can be resumed, within a DelegationTasks owner or with SubAgents.task_control set.
Set this to False for a one-shot agent. DelegationTasks(one_shot=...) does the same by name, for an owner
the application binds.
Type: bool Default: dataclass_field(default=True, kw_only=True)
Whether the sub-agent gets an ask_parent tool to ask the delegating agent a question, with
SubAgents.task_control set. Not offered when the task can’t run in the background.
Type: bool Default: dataclass_field(default=True, kw_only=True)
The delegate’s name: name if set, else the agent’s own name.
One entry on the model menu, as a model plus how it should run.
Pass bare model references when the menu keys speak for themselves, and a
ModelOption when an entry needs a routing hint or its own settings:
from pydantic_ai.settings import ModelSettings
from pydantic_ai_harness.subagents import ModelOption, SubAgents

SubAgents(
    models={
        'fast': 'anthropic:claude-haiku-4-5',
        'deep': ModelOption(
            'anthropic:claude-opus-4-7',
            description='hard reasoning, multi-file changes',
            settings=ModelSettings(thinking='xhigh'),
        ),
    },
)
The model a delegation routed to this option runs on.
Type: Model | KnownModelName | str
What this option is for, listed in the prompt next to the key so the parent can route on task difficulty rather than on model names alone.
Type: str | None Default: None
Settings for a delegation routed to this option — thinking effort,
temperature, and so on. They merge over the sub-agent’s own model_settings,
which keeps whatever the sub-agent set and is not overridden here.
Type: ModelSettings | None Default: None
Per-agent override for a disk-loaded sub-agent, keyed by the agent’s name.
Both fields are optional. An unset model inherits the parent run’s model; an
unset effort leaves the inherited model’s thinking setting unchanged.
Model to run this disk agent with, in place of inheriting the parent’s.
Type: Model | KnownModelName | str | None Default: None
Thinking/reasoning level for this disk agent, passed through unchanged.
Type: ThinkingLevel | None Default: None
Bases: CapabilityEvent
A sub-agent run is about to start for one delegation.
Emitted once the delegation has passed every check that could refuse it (an
unknown sub-agent, a model key off the menu, an exhausted max_calls
budget), immediately before the child run starts.
The menu key the delegation runs on, or None when no option was selected: there is
no menu, or the delegate allows the whole menu and the parent named no key.
The task whose run started this one, or None when the top-level run did.
Type: _ParentTaskId Default: None
Whether the parent’s own tools were passed to the child run (SubAgents.inherit_tools).
Type: bool
Bases: CapabilityEvent
A delegation settled into what the parent receives.
output is what the delegate tool hands back to the parent: the child’s
output on ok, otherwise the steering message it returns or the
ModelRetry it raises. An exception that propagates out of the delegate
tool (a shared usage limit, an uncontained crash, a cancellation) ends
without this event for ordinary SubAgents users. An opt-in DelegationTasks
owner emits terminal cancelled or error outcomes with stable task identity.
The child’s own usage when it has separate accounting (SubAgent.usage_limits
set, or forward_usage off); None when it accrues into the parent’s usage.
The task whose run started this one, or None when the top-level run did.
Type: _ParentTaskId Default: None
Wall-clock milliseconds from just after the start event was emitted until the delegation settled.
Type: float
Deprecated: duration_ms in seconds.
Type: float
Lets delegations outlive the tool call, and gives the model tools to manage them.
Every run gets a DelegationTasks owner unless the application bound one, so delegate_task takes
background and resume, and the model gets list_tasks, message_task, answer_task and
cancel_task. A sub-agent gets an ask_parent tool (SubAgent.can_ask_questions). Each step of a
task is a SubAgentMessageEvent that listeners can rewrite or veto, and the reports of background
tasks arrive as messages: a top-level run that would end while its own background tasks work waits
for them.
Sub-agents a SubAgentWorker in another process serves, reached through transport.
Type: Sequence[RemoteSubAgent] Default: ()
How messages reach the SubAgentWorker serving remote_agents. Required with remote_agents.
Type: SubAgentTransport | None Default: None
How many seconds a remote task waits for a worker to pick it up before it fails, or None to wait
indefinitely.
Type: float | None Default: 30.0
How many seconds delegate_task waits for a task before it returns a receipt and lets the task
continue in the background. None waits until the task settles.
Type: float | None Default: None
The most tasks a conversation may have running when it starts another, across its whole delegation
tree, or None for no limit.
Type: int | None Default: None
Forward the events of every task’s run into the delegating run’s event stream, as
TaskProgressEvents.
Type: bool Default: False
A sub-agent that a SubAgentWorker in another process serves, reached through TaskControl.transport.
The worker runs the agent with its own model, tools and deps; this side only knows its name and what it is for.
The name the model delegates to, and the worker serves it under. 1 to 64 letters, digits, _ or -.
Type: str
What the agent is good at, for the system-prompt listing.
Type: str | None Default: None
Whether a finished task can be resumed, continuing the conversation the worker keeps.
The conversation lives in the worker that ran the task, so serve each remote agent name from one worker: another worker that picks up the follow-up fails the task, having no conversation to resume.
Type: bool Default: True
Whether the agent gets an ask_parent tool to ask the delegating agent a question.
Type: bool Default: True
Bases: Generic[AgentDepsT]
Serves sub-agents to delegating agents in other processes, over a transport.
Run serve in the process that hosts the agents. The delegating agent’s SubAgents lists them as
RemoteSubAgents with the same names, and reaches them through the same transport.
The worker keeps the conversations of tasks, up to max_conversations, so a delegating run can
resume them.
The agents this worker serves, by the name delegating agents reach them by.
Run controls such as usage limits or timeouts belong to the agent, or to the delegating run’s
SubAgents, which applies its own to the task.
Type: Mapping[str, AbstractAgent[AgentDepsT, object]]
The transport the delegating agents send tasks over.
Type: SubAgentTransport
The deps every task’s run gets. Deps never cross the transport.
Type: AgentDepsT
How many times to run a task again when its run raises an error, starting over from its prompt.
Cancellation, usage limits, and UserError are not retried.
Type: int Default: 0
How many task conversations to keep for resuming; the least recently used is forgotten first.
Type: int Default: 1000
@async
def serve() -> None
Receive and run tasks for every agent, until cancelled.
Bases: ABC
Carries SubAgentMessageEvents between a delegating run and the SubAgentWorker serving its remote agents.
A transport is a set of mailboxes. send delivers a message to the mailbox named by its mailbox
property, and receive waits for the next message in a mailbox. Messages a mailbox receives before
anyone waits on it are kept, in order.
The delegating run relays a task’s messages until the task settles, so the worker must end every task it
picks up with one TaskSettledEvent (TaskCompletedEvent, TaskFailedEvent or TaskCancelledEvent) to
its parent mailbox. SubAgentWorker does, including when it stops.
Implement this class to reach agents in other processes or machines, over a WebSocket, gRPC, a Redis
list, or anything else that can move bytes: use serialize_message and deserialize_message at the
boundary. InMemoryTransport serves a worker in the same process.
The transport is the trust boundary: anyone who can send to it can run the served agents, with their tools and dependencies. Authenticate and authorize senders in the transport.
@abstractmethod
@async
def send(message: SubAgentMessageEvent) -> None
Deliver message to message.mailbox, without waiting for anyone to receive it.
@abstractmethod
@async
def receive(mailbox: str) -> SubAgentMessageEvent
Wait for the next message delivered to mailbox and return it, in the order they were sent.
A stopping worker reports its running tasks as failed. Raise once a worker is gone without doing so, if the transport can tell: otherwise its delegating run waits for the task until it is cancelled.
SubAgentMessageEvent
@async
def release(mailbox: str) -> None
Discard mailbox and any messages left in it, once no one will receive from it again.
Called when a task settles, for its two task mailboxes. The default does nothing.
A message sent after the release, such as the late reply of a worker to a task that timed out, starts the mailbox again, and nobody may receive it. A transport that serves many tasks should expire such messages, for example with a time to live.
Bases: SubAgentTransport
A transport whose mailboxes are in-process queues, for a worker in the same process.
Messages are passed by reference, not serialized.
def __init__() -> None
Create a transport with no mailboxes; each is created when first sent to or received from.
@async
def send(message: SubAgentMessageEvent) -> None
Append message to its mailbox’s queue and wake whoever waits on that mailbox.
@async
def receive(mailbox: str) -> SubAgentMessageEvent
Take the oldest message in mailbox, waiting until one arrives.
SubAgentMessageEvent
@async
def release(mailbox: str) -> None
Drop mailbox and any messages still queued in it.
def serialize_message(message: SubAgentMessageEvent) -> bytes
Serialize a sub-agent message to JSON, for a transport that crosses a process boundary.
def deserialize_message(data: str | bytes) -> SubAgentMessageEvent
Deserialize a sub-agent message serialized by serialize_message.
SubAgentMessageEvent
ValueError— Ifdatais not a sub-agent message.
Bases: Generic[AgentDepsT]
Lets the model create sub-agents during a run, with a create_agent tool.
A created sub-agent is delegated to like any other, by the run that created it, until that run ends.
The SubAgents.models keys the model may run a created sub-agent on; the first is the default.
Empty: created sub-agents run on the delegating run’s model.
Type: Sequence[str] Default: ()
How many sub-agents one run may create.
Type: int Default: 5
Builds the agent. The default is an Agent with the requested instructions and no tools, on the
model SubAgents routes the delegation to.
The model wrote the spec’s name and description. Tracing records an agent’s own name and description
even without content, so the default agent has neither.
Type: DynamicAgentFactory[AgentDepsT] | None Default: None
What the model asked for when it called create_agent.
The new sub-agent’s name.
Type: str
What the sub-agent is for.
Type: str
The sub-agent’s instructions, written by the model.
Type: str
The SubAgents.models key the sub-agent runs on, or None for the delegating run’s model.
Builds the agent for a sub-agent the model created with create_agent.
Type: TypeAlias Default: 'Callable[[DynamicAgentSpec], AbstractAgent[AgentDepsT, Any]]'
Bases: CapabilityEvent
A message between a delegating run and one of its tasks, with SubAgents(task_control=...).
Messages are dispatched immediately: listeners run before the message takes effect, so they can
rewrite its fields or, for a ParentMessageEvent, veto it. A SubAgentTransport carries them to and
from a SubAgentWorker in another process.
Which side of the task receives this message.
Type: Recipient
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
Bases: _Vetoable, SubAgentMessageEvent
A message from a delegating run to its task. A listener can veto it, and then it has no effect.
Bases: SubAgentMessageEvent
A message from a task to its delegating run.
Which side of a task a message is for: the worker serving the agent, the running task, or its parent.
Type: TypeAlias Default: Literal['worker', 'task', 'parent']
Bases: ChildMessageEvent
The task’s run ended. This is the task’s report to its delegating run.
The sub-agent’s usage when a worker in another process counted it separately.
None for a sub-agent that ran in the delegating run’s process: its usage was counted the way
SubAgents.forward_usage and SubAgent.usage_limits decide.
Type: RunUsage | None Default: None
Why a task moved to the background.
requested: the model delegated withbackground=True.auto: the task ran longer thanTaskControl.auto_background_after.question: the task asked a question, which the delegating model can only answer once the delegation tool returns.
Type: TypeAlias Default: Literal['requested', 'auto', 'question']
Bases: ParentMessageEvent
A request to a worker to start a run of the sub-agent: a new task or a follow-up.
Not to be confused with TaskStartedEvent, the worker’s reply once the run started.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
What the sub-agent is asked to do. A listener can rewrite it.
Type: str
The task whose run started this one, or None when the top-level run did.
Type: str | None Default: None
The delegation level the task runs at, counting the top-level run as 1, like SubAgents.max_depth.
Type: int Default: 2
Whether the sub-agent gets an ask_parent tool.
Type: bool Default: True
Whether the sub-agent’s stream events are forwarded as TaskProgressEvents.
Type: bool Default: False
The delegating run’s usage limits, which a worker in another process applies to the sub-agent’s own usage.
Type: UsageLimits | None Default: None
W3C trace context of the delegation, so a worker in another process continues the delegating run’s trace.
Type: dict[str, str] Default: field(default_factory=(dict[str, str]))
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: TaskRequestEvent
The delegating run assigns a new task to a sub-agent.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
What the sub-agent is asked to do. A listener can rewrite it.
Type: str
The task whose run started this one, or None when the top-level run did.
Type: str | None Default: None
The delegation level the task runs at, counting the top-level run as 1, like SubAgents.max_depth.
Type: int Default: 2
Whether the sub-agent gets an ask_parent tool.
Type: bool Default: True
Whether the sub-agent’s stream events are forwarded as TaskProgressEvents.
Type: bool Default: False
The delegating run’s usage limits, which a worker in another process applies to the sub-agent’s own usage.
Type: UsageLimits | None Default: None
W3C trace context of the delegation, so a worker in another process continues the delegating run’s trace.
Type: dict[str, str] Default: field(default_factory=(dict[str, str]))
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: TaskRequestEvent
The delegating run resumes a finished task’s conversation with a new prompt.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
What the sub-agent is asked to do. A listener can rewrite it.
Type: str
The task whose run started this one, or None when the top-level run did.
Type: str | None Default: None
The delegation level the task runs at, counting the top-level run as 1, like SubAgents.max_depth.
Type: int Default: 2
Whether the sub-agent gets an ask_parent tool.
Type: bool Default: True
Whether the sub-agent’s stream events are forwarded as TaskProgressEvents.
Type: bool Default: False
The delegating run’s usage limits, which a worker in another process applies to the sub-agent’s own usage.
Type: UsageLimits | None Default: None
W3C trace context of the delegation, so a worker in another process continues the delegating run’s trace.
Type: dict[str, str] Default: field(default_factory=(dict[str, str]))
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: ChildMessageEvent
A worker picked the task up and its run is starting.
A remote task that no worker picks up within TaskControl.accept_timeout fails.
Bases: CapabilityEvent
A task now runs in the background: the delegation tool returned a receipt, and its report arrives later.
A requested task still running when the delegation tool gets its receipt, but settled before this event is
announced, as one replayed under durable execution can be, gets this event after its settle event.
The task now running in the background.
Type: str
The name of the sub-agent running the task.
Type: str
Why it moved to the background.
Type: BackgroundReason
Bases: ChildMessageEvent
An event from the sub-agent’s own run, forwarded while the task runs, with TaskControl.forward_events.
Dispatched at its stream position, like the event it carries.
The sub-agent’s stream event.
Type: AgentStreamEvent
Bases: ChildMessageEvent
The task asks its delegating run a question and waits for a TaskAnsweredEvent.
A listener can answer it by setting answer, and then the delegating model is not asked.
Identifies the question, so the answer can name it.
Type: str
The question.
Type: str
An answer a listener supplies, sent to the task without involving the delegating model.
Type: str | None Default: None
Bases: ParentMessageEvent
The delegating run answers the question a task is waiting on.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
The TaskQuestionAskedEvent.question_id this answers.
Type: str
The answer. A listener can rewrite it.
Type: str
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: ParentMessageEvent
The delegating run steers a running task, which sees the message at its next model request.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
The steering message. A listener can rewrite it.
Type: str
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: ParentMessageEvent
The delegating run asks a running task to stop before its next model request.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: ParentMessageEvent
The delegating run stops a running task immediately, interrupting its current model request or tool calls.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: ChildMessageEvent
A remote task’s run failed and its worker is running it again, as SubAgentWorker.retries allows.
The attempt about to start; the first retry is attempt 2.
Type: int
The error the previous attempt failed with.
Type: str
Bases: TaskSettledEvent
The task finished with an output.
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
The sub-agent’s usage when a worker in another process counted it separately.
None for a sub-agent that ran in the delegating run’s process: its usage was counted the way
SubAgents.forward_usage and SubAgent.usage_limits decide.
Type: RunUsage | None Default: None
The sub-agent’s output, as text. A listener can rewrite it before the delegating model reads it.
Type: str
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: TaskSettledEvent
The task’s run failed, or ended in a way that delivered no output.
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
The sub-agent’s usage when a worker in another process counted it separately.
None for a sub-agent that ran in the delegating run’s process: its usage was counted the way
SubAgents.forward_usage and SubAgent.usage_limits decide.
Type: RunUsage | None Default: None
What went wrong, as reported to the delegating model.
Type: str
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: TaskSettledEvent
The task stopped because it was cancelled. A resumable task can be followed up on.
The task this message belongs to.
Type: str
The name of the sub-agent running the task.
Type: str
The address a transport delivers this message to.
agent:<agent_name> for a message that starts a run, task:<task_id>:worker for one the running
task receives, and task:<task_id>:parent for one its parent receives.
Type: str
The sub-agent’s usage when a worker in another process counted it separately.
None for a sub-agent that ran in the delegating run’s process: its usage was counted the way
SubAgents.forward_usage and SubAgent.usage_limits decide.
Type: RunUsage | None Default: None
Whether the task was stopped immediately rather than before its next model request.
Type: bool
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema
Bases: _Vetoable, CapabilityEvent
The model is creating a sub-agent with create_agent (SubAgents.dynamic_agents).
Dispatched immediately, so a listener can rewrite description and instructions, or veto the
creation.
Whether a listener vetoed it.
Type: bool Default: False
Why it was vetoed, reported to the model that asked for it.
Type: str | None Default: None
The name the model gave the sub-agent, which it delegates to.
Also loads from name, the key it was serialized under before the rename.
Type: Annotated[str, Field(validation_alias=(AliasChoices(‘agent_name’, ‘name’)))]
What the sub-agent is for. It reaches only a custom DynamicAgents.factory, as DynamicAgentSpec.description;
the model is never shown it. A listener can rewrite it.
Type: str
The sub-agent’s instructions. A listener can rewrite them.
Type: str
The SubAgents.models key the sub-agent runs on, or None for the delegating run’s model.
When capability and application listeners receive the event.
Type: Literal[‘stream’, ‘immediate’] Default: 'stream'
The namespaced event kind, injected as the default on registered subclasses.
Type: str Default: ''
The run id of the capability that emitted this event.
Stamped at emission when unset; a pre-set value is preserved, so a capability re-emitting an event on behalf of another instance can keep the original attribution.
Type: str | None Default: None
The associated tool call id, when emitted by a capability-contributed tool.
Type: str | None Default: None
The associated tool name, when emitted by a capability-contributed tool.
Type: str | None Default: None
Event type identifier, used as a discriminator.
Type: Literal[‘capability’] Default: 'capability'
def veto(reason: str | None = None) -> None
Stop it from taking effect.
@classmethod
def __get_pydantic_core_schema__(
    cls,
    source: Any,
    handler: pydantic.GetCoreSchemaHandler,
) -> pydantic_core.core_schema.CoreSchema
Build this family’s tagged union, instead of the plain dataclass schema pydantic would infer.
The set of event classes isn’t known when this module is imported — applications and
capabilities register their own by defining them — so the union can’t be written down as a
static Annotated[... , Field(discriminator=...)] the way the closed event types are. This
override builds it from the registry each time a schema is generated, and routes a tag no
class has registered to UnknownCapabilityEvent, so an event from a process that
imported a module this one didn’t still round-trips instead of failing validation.
Only the family base builds the union; a subclass gets its own dataclass schema, so annotating a concrete event type validates just that event.
pydantic_core.core_schema.CoreSchema